Selected Publications
1
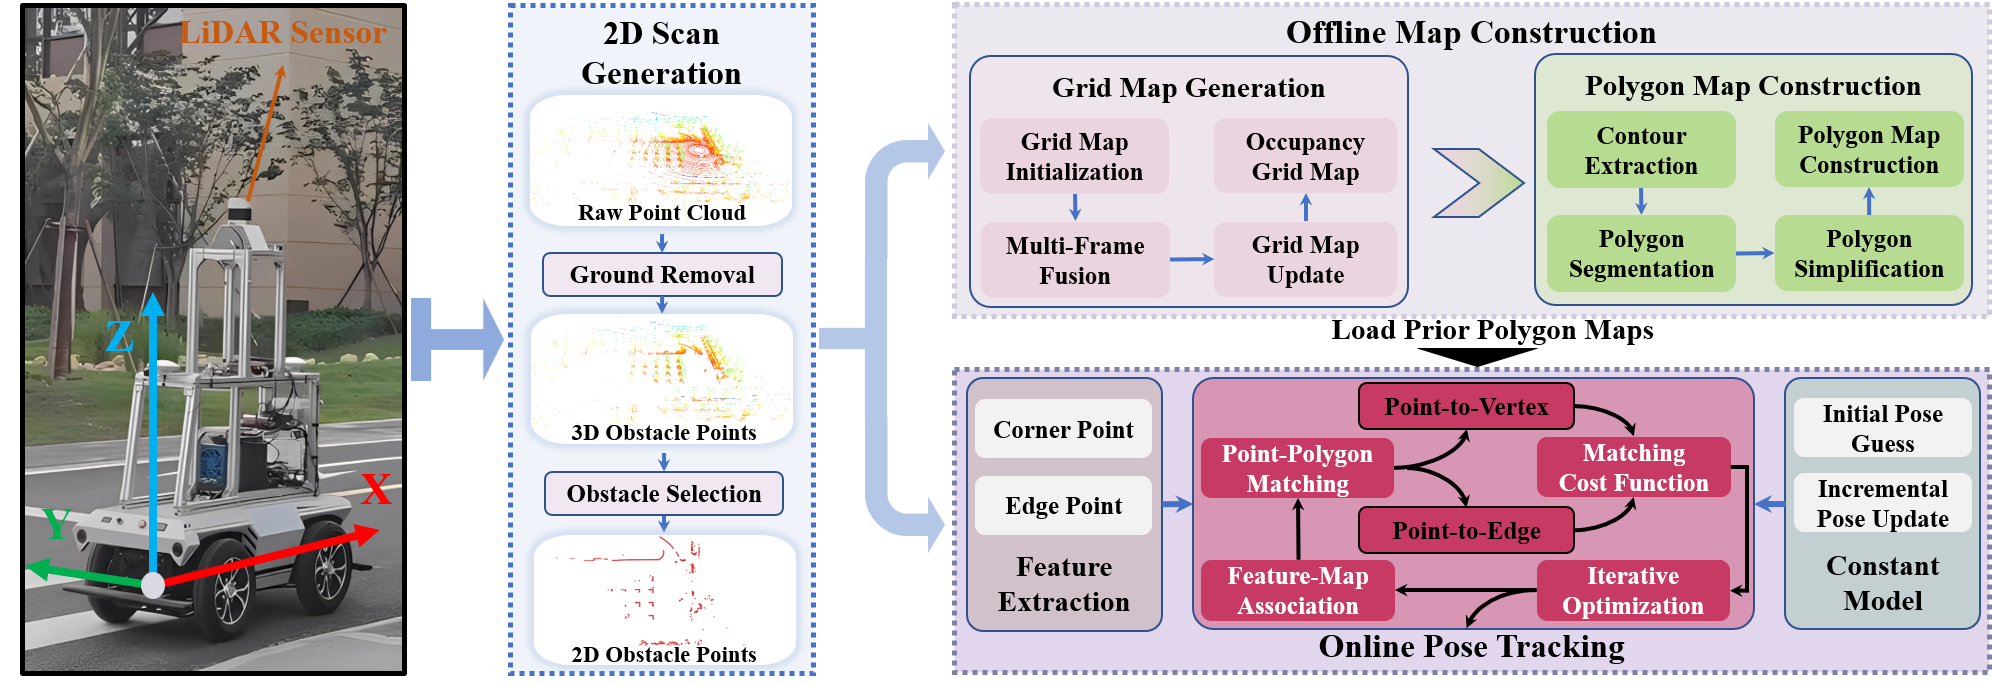
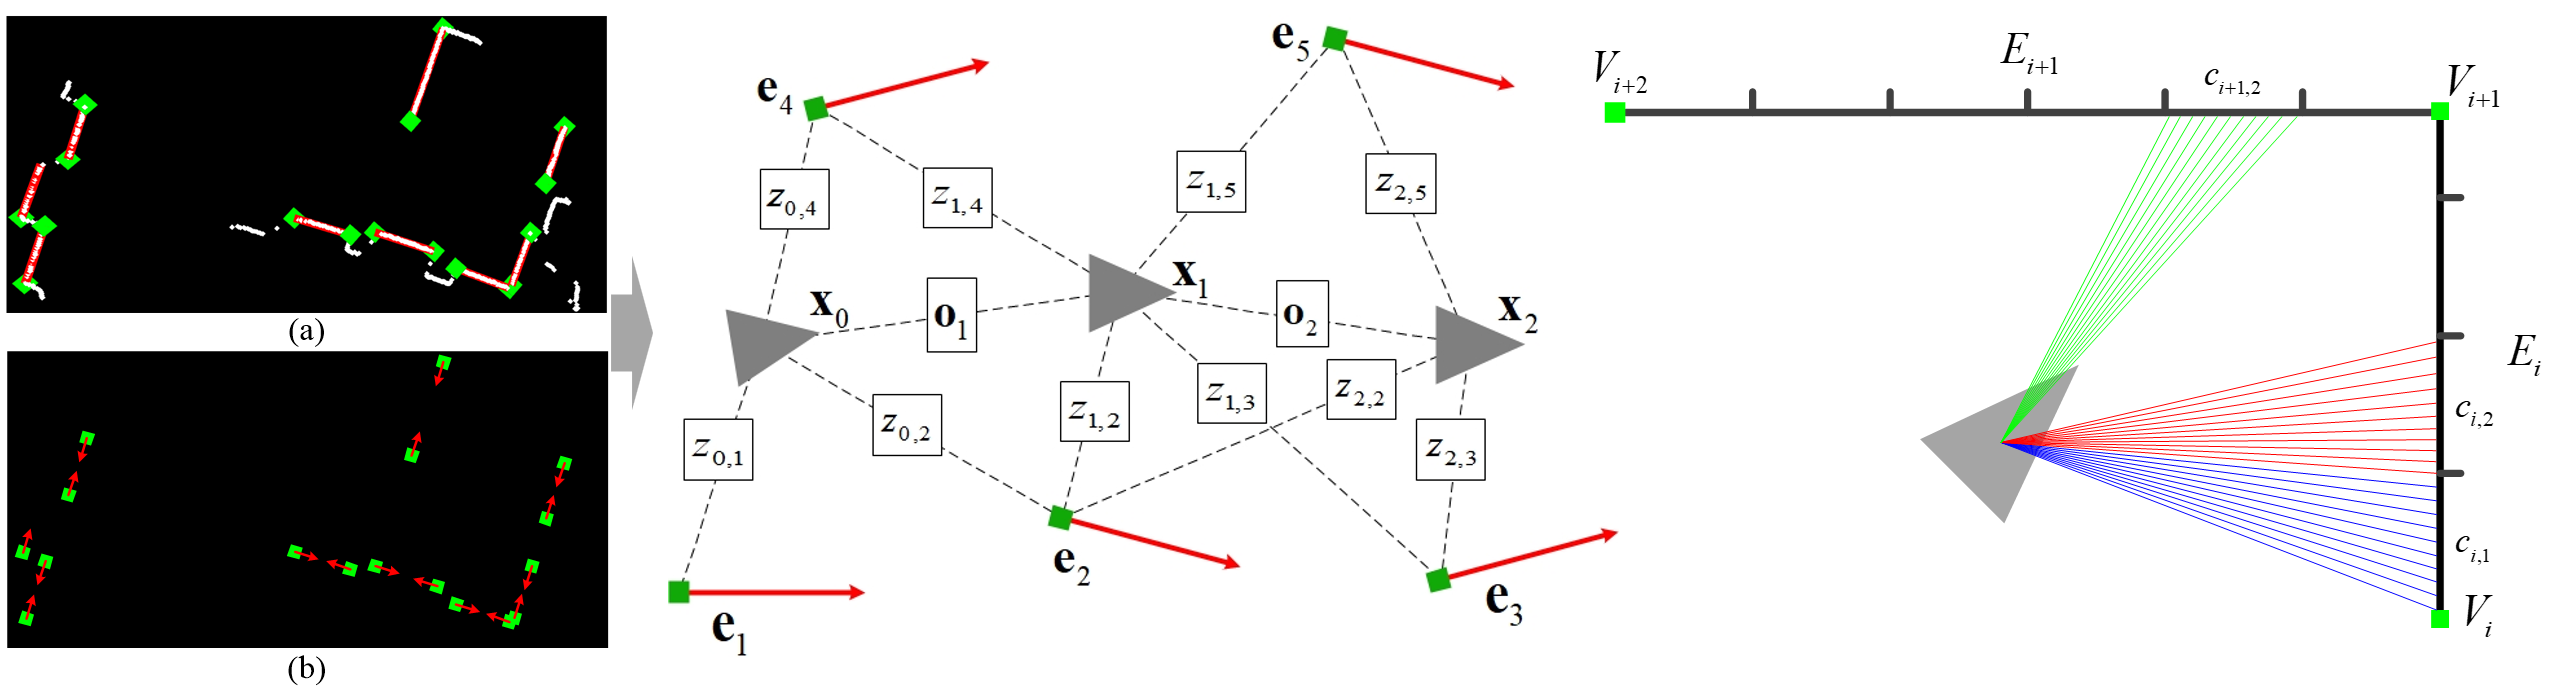
H. Gao, Q. Qiu, H. Liu, D. Liang*, C. Wang, and X. Zhang, ERPoT: Effective and reliable pose tracking for mobile robots using lightweight polygon maps
IEEE Transactions on Robotics, 2025, 41: 3799-3819
2
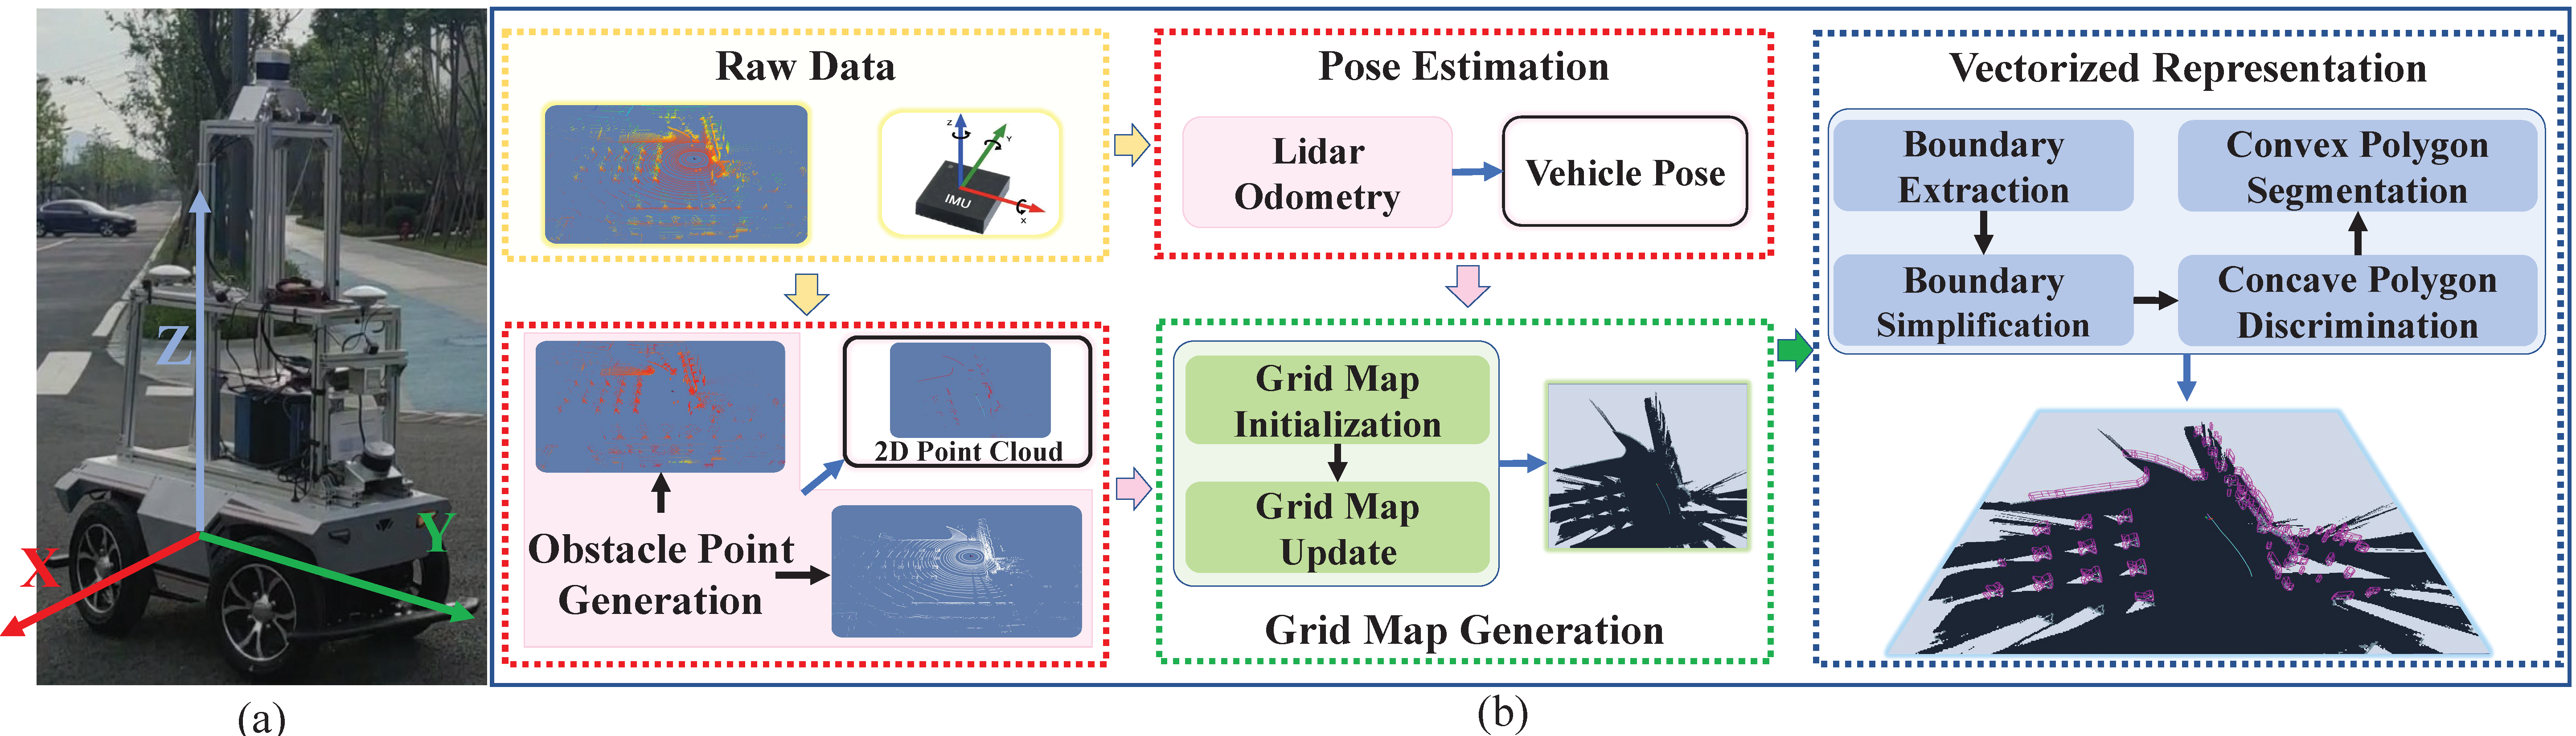
H. Gao, Q. Qiu, W. Hua*, X. Zhang, Z. Su, S. Zhang, CVR-LSE: Compact vectorized representation of local static environments for reliable obstacle detection
IEEE Transactions on Industrial Electronics, 2024, 71(8): 9309-9318
3
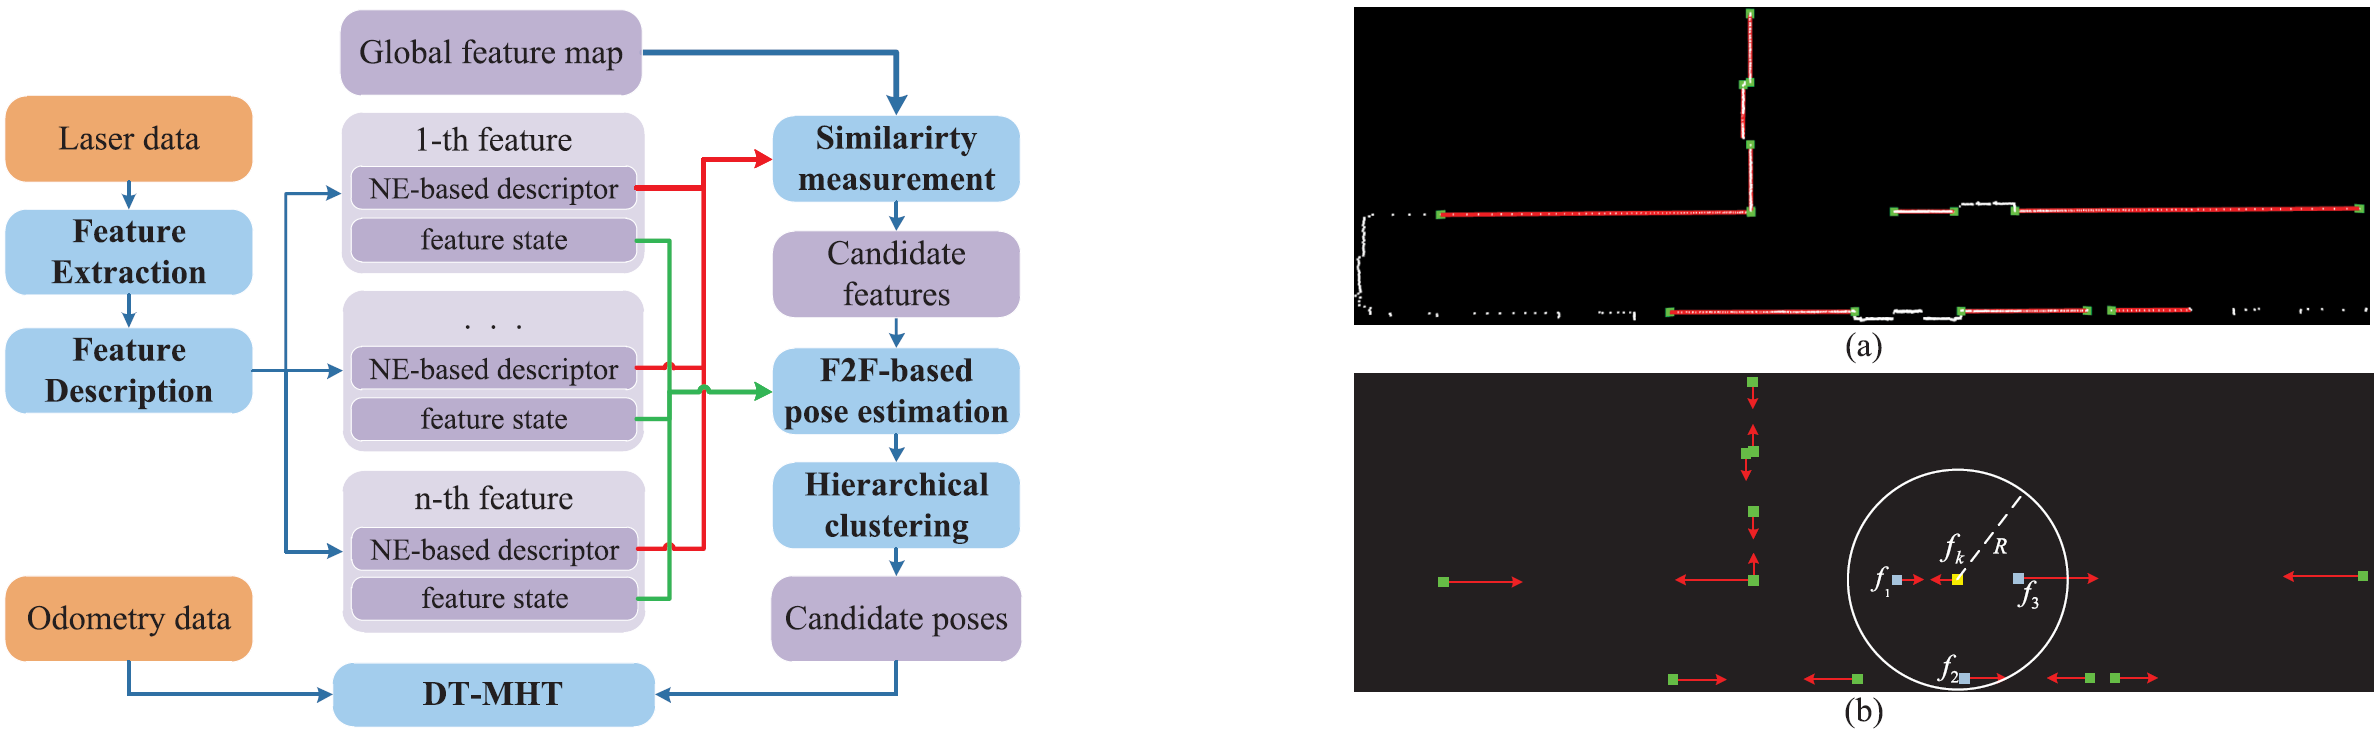
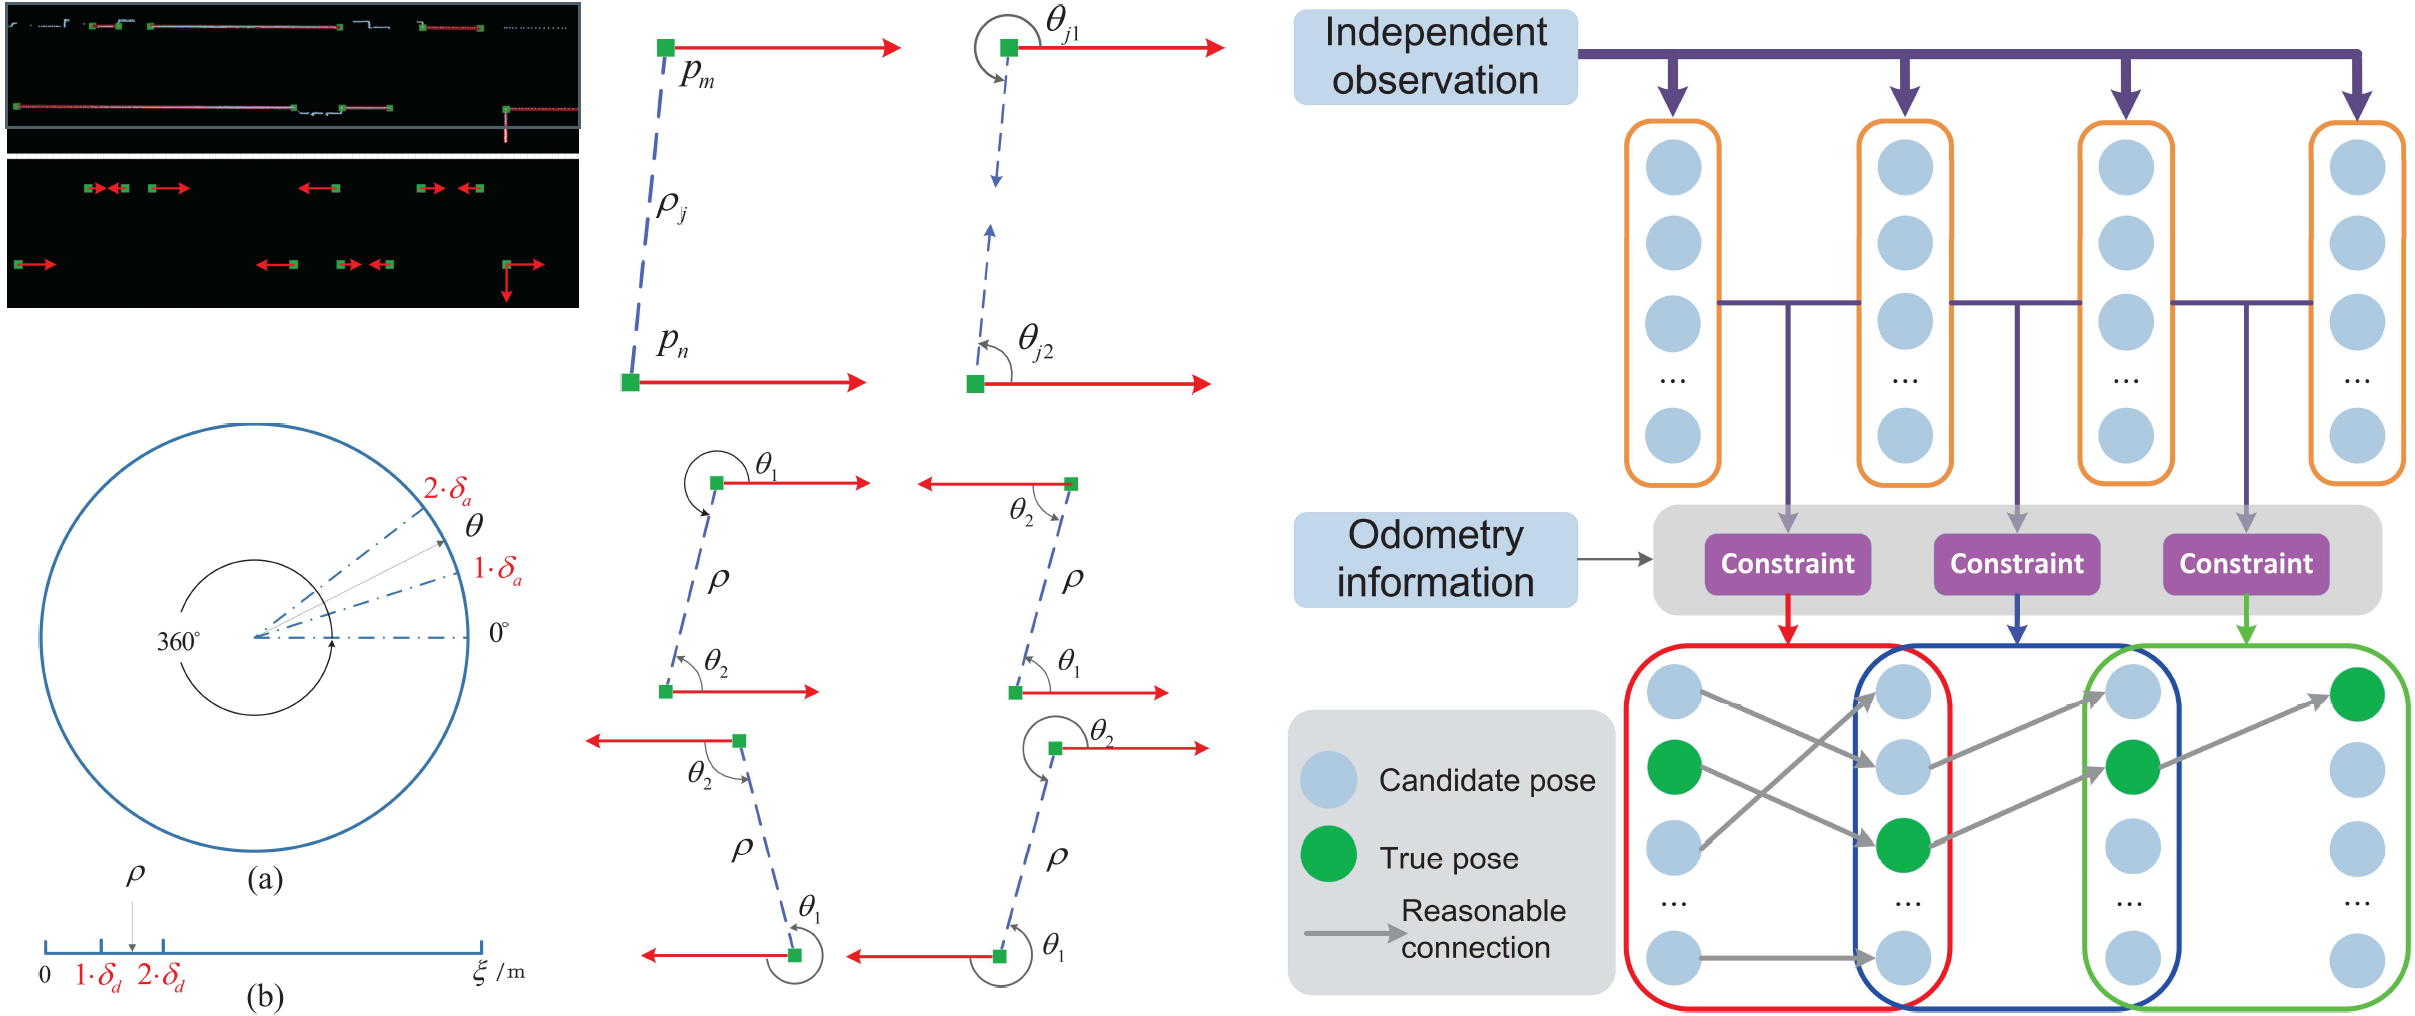
H. Gao, X. Zhang*, J. Yuan, and Y. Fang. NEGL: Lightweight and efficient neighborhood encoding-based global localization for unmanned ground vehicles
IEEE Transactions on Vehicular Technology, 2023, 72(6): 7111-7122
4
H. Gao, X. Zhang*, J. Yuan, J. Song, and Y. Fang. A novel global localization approach based on structural unit encoding and multiple hypothesis tracking
IEEE Transactions on Instrumentation and Measurement, 2019, 68(11): 4427-4442
5
H. Gao, X. Zhang*, J. Wen, J. Yuan, and Y. Fang. Autonomous indoor exploration via polygon map construction and graph-based SLAM using directional endpoint features
IEEE Transactions on Automation Science and Engineering, 2019, 16(4): 1531-1542
6
H. Gao, X. Zhang*, Y. Fang, and J. Yuan. A line segment extraction algorithm using laser data based on seeded region growing
International Journal of Advanced Robotic Systems, 2018, 15(1): 1-10
Most Read Articles
7
Q. Qiu, W. Wang, H. Ying, D. Liang, H. Gao*, and X. He. Stacked asymmetric convolution and selective feature fusion for large-scale point cloud-based place recognition
Knowledge-Based Systems, 2024, 295: 111794
8
F. Guo, H. Gao, X. Xi, G. Zhang, W. Hua, J. Lu, ..., and D. Li. A unified gradients-informed consistency model for 3D scene-aware planning and generation tasks
IEEE Transactions on Multimedia, 2026, doi: 10.1109/TMM.2026.3740564 (Early Access)
9
H. Gao, X. Zhang*, C. Li, X. Chen, Y. Fang, and X. Chen. Directional endpoint-based enhanced EKF-SLAM for indoor mobile robots
IEEE/ASME International Conference on Advanced Intelligent Mechatronics, pp. 978-983, 2019
10
H. Gao, Q. Qiu, S Zhang, W. Hua*, Z. Su, and X. Zhang. MPC-MF: Multi-point cloud map fusion based on offline global optimization for mobile robots
2023 Chinese Control Conference (CCC), pp. 4237-4242, 2023
11
Q. Qiu, H. Yang, J. Jiang, S. Zhang, H. Ying, H. Gao, W. Wang, and X. He. M³CS: Multi-target masked point modeling with learnable codebook and siamese decoders
IEEE Transactions on Circuits and Systems for Video Technology, 2025, doi: 10.1109/TCSVT.2025.3553525
12
Y. Song, R. Wang, Q. Bi, Z. Pan, H. Gao, and X. Zhang. STVO: Spatial-temporal constrained velocity obstacle for safe navigation among pedestrians
IEEE Transactions on Vehicular Technology, 2025, doi: 10.1109/TVT.2025.3565734
13
H Liu, H. Gao, J. Shi, C. Xu, D. Qu, and W. Hua. APMC-LOM: Accurate 3D LiDAR odometry and mapping based on pyramid warm-up registration and multi-constraint optimization
IEEE Transactions on Vehicular Technology, 2024, 73(12): 18266-18282
14
Q. Qiu, H. Gao, W. Hua, G. Huang, and X. He. PriorLane: A prior knowledge enhanced lane detection approach based on transformer
IEEE International Conference on Robotics and Automation (ICRA), pp. 5618-5624, 2023
15
J. Wen, X. Zhang*, H. Gao, J. Yuan, and Y. Fang. E³MoP: Efficient motion planning based on heuristic-guided motion primitives pruning and path optimization with sparse-banded structure
IEEE Transactions on Automation Science and Engineering, 2022, 19(4): 2762-2775
16
C. Li, X. Zhang*, H. Gao, R. Wang, and Y. Fang. Bridging the gap between visual servoing and visual SLAM: A novel integrated interactive framework
IEEE Transactions on Automation Science and Engineering, 2022, 19(3): 2245-2255
17
J. Wen, X. Zhang*, H. Gao, J. Yuan, and Y. Fang. CAE-RLSM: Consistent and efficient redundant line segment merging for online feature map building
IEEE Transactions on Instrumentation and Measurement, 2020, 69(7): 4222-4237
18
Q. Qiu, S. Zhang, H. Gao, H. Yang, H. Ying, W. Wang, and X. He. EMVP: Embracing visual foundation model for visual place recognition with centroid-free probing
Advances in Neural Information Processing Systems (NeurIPS), 2024, 37: 120928-120950
19
Y. Zhu, W. Lu, G. Ren, H. Gao, S. Vougioukas, Y. Ying, and C. Peng. Optimal scheduling of a dual-arm robot for efficient strawberry harvesting in plant factories
2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), pp. 1231-1238, 2025
20
Z. Ge, P. Wei, W. Lu, K. Shi, F. Yang, Z. Man, H. Gao, Y. Ying, and C. Peng. Fast deployable robust control for structured offshore aquaculture platforms inspection with adaptive disturbance compensator
Biomimetic Intell. Robot., 2026, 6(4): 100311
21
周光召, 苑晶*, 高海明, 孙沁璇, 张雪波, 俞诗卓. 结构化环境下基于结构单元软编码的3维激光雷达点云描述子
机器人, 2020, 42(06): 641-650
22
J. Song, H. Gao, X. Zhang*, W. Lin, and J. Liu. A global localization algorithm for mobile robots based on grid submaps
IEEE International Conference on Advanced Robotics and Mechatronics, pp. 201-206, 2018
Best Conference Paper Finalist
23
J. Wen, X. Zhang*, H. Gao, J. Yuan, and Y. Fang. A novel 2D laser scan matching algorithm for mobile robots based on hybrid features
IEEE International Conference on Real-time Computing and Robotics, pp. 366-371, 2018
Best Paper Award Finalist
24
J. Wang, X. Zhang*, H. Gao, and Y. Fang. Time-optimal motion planning for a nonholonomic mobile robot on a barcode map
IEEE International Conference on Robotics and Biomimetics, pp. 215-220, 2017
... and more publications in progress